Overview
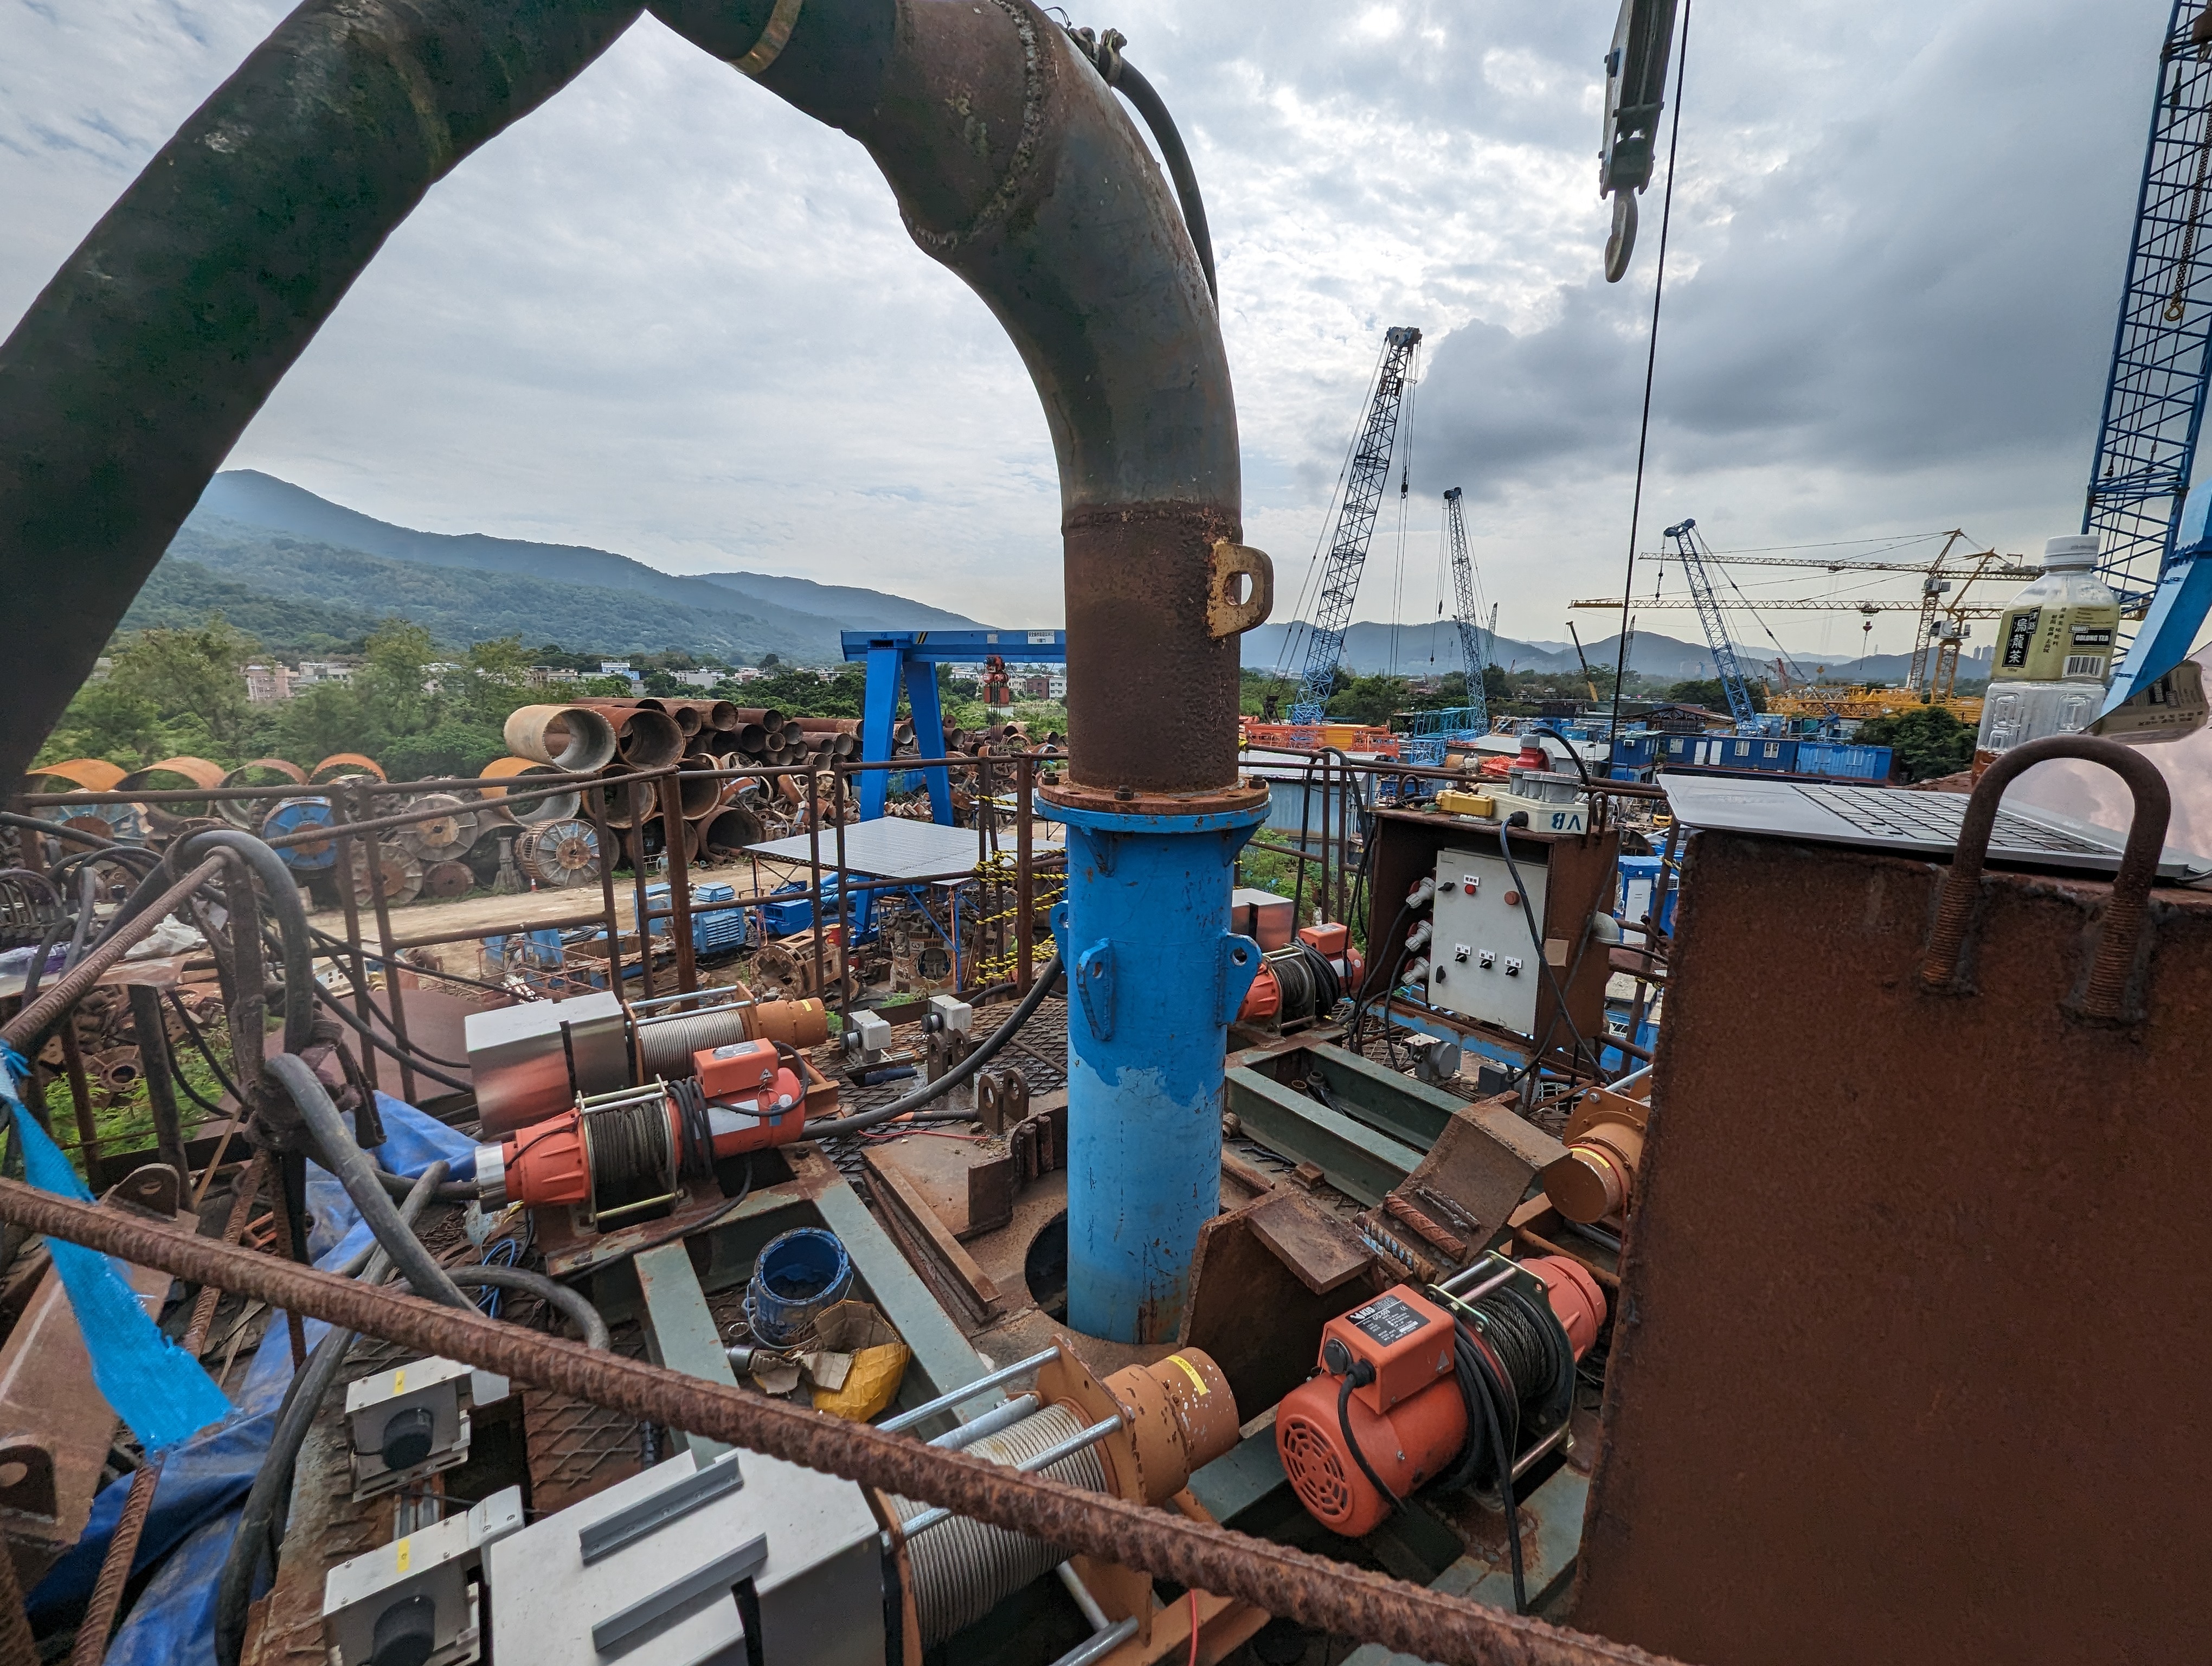
A cable-suspended robotic platform for cleaning and inspecting deep foundations, developed at CUHK. The project explored an alternative to high-cost Reverse Circulation Drilling methods, using synchronised cables to lower and control the platform.
Patent: US 12,398,527 B2 — View on Google Patents →
Platform And Flexible-Hose Control
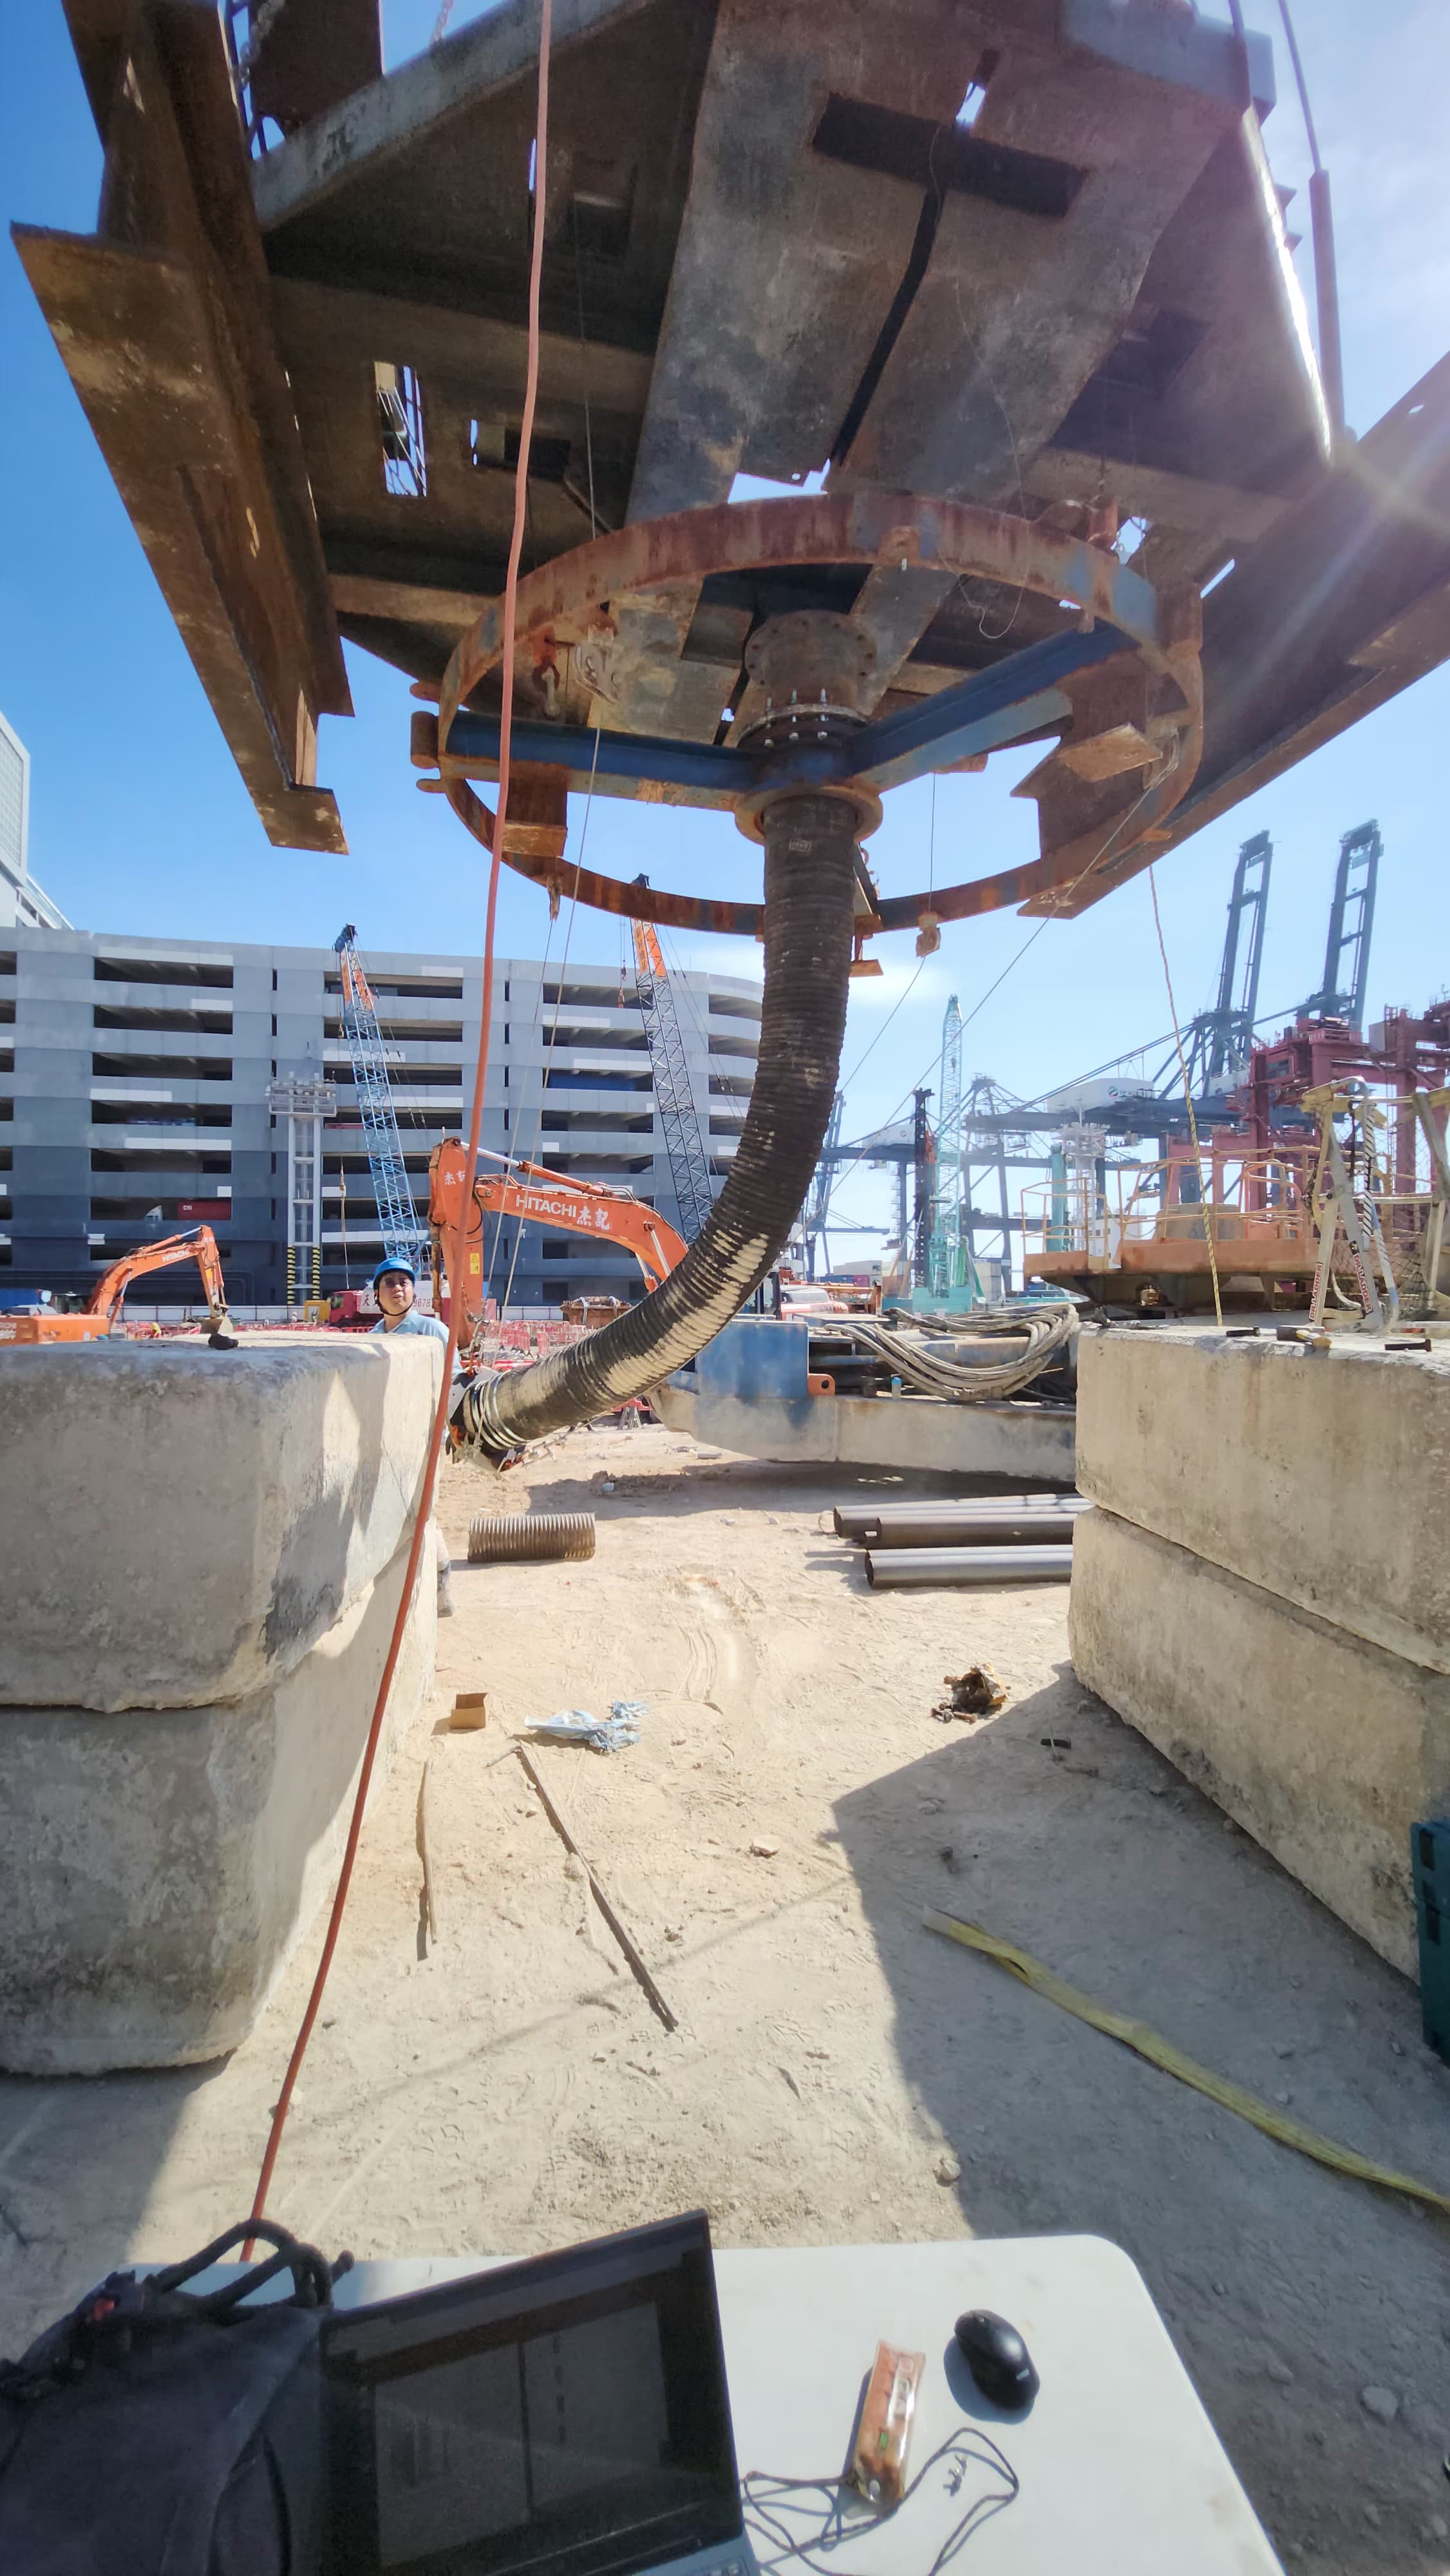
The work involved two control problems: positioning a suspended inspection platform with synchronised winches, and controlling a flexible air-lift cleaning hose through cable actuation. The hose’s deformable behaviour had to be considered in the modelling and control approach.
My Contribution
As a Research Assistant at CUHK (Dec 2022 – Mar 2024), I developed control software and ran field tests:
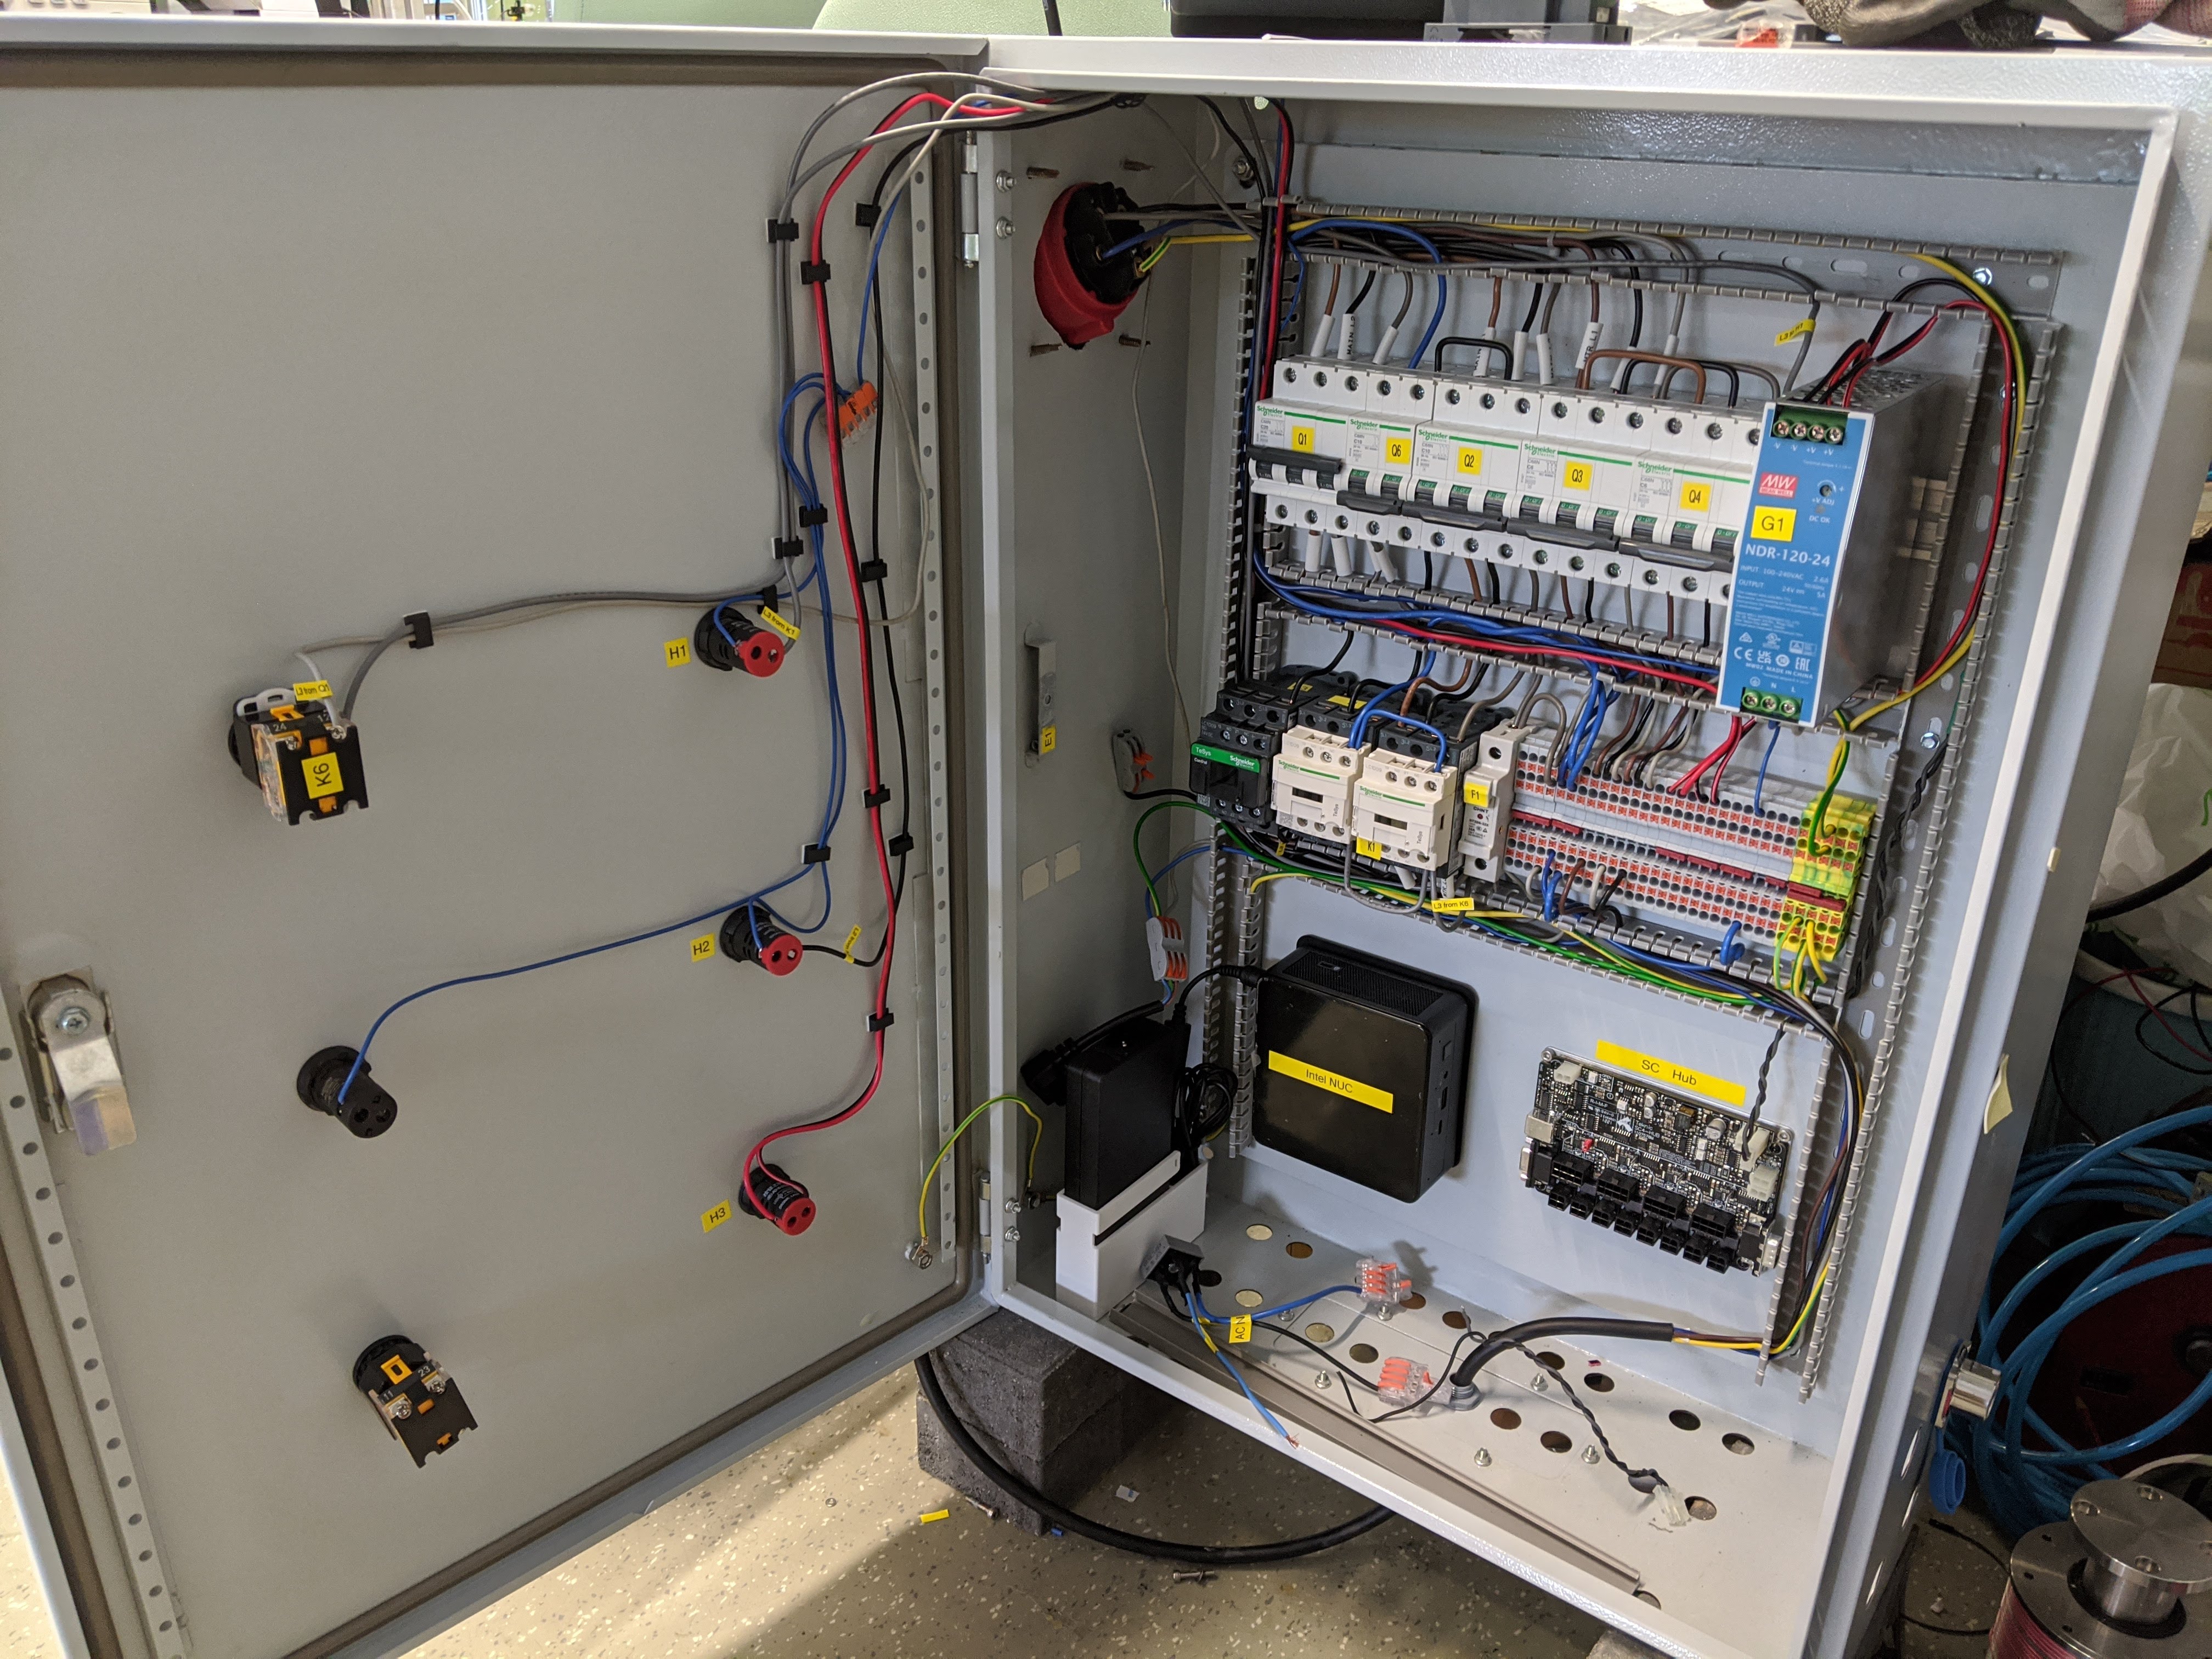
- Programmed synchronised winch control for the suspended platform, with testing at 15 metres deployment depth.
- Implemented control for the cable-actuated flexible hose, taking hose modelling into account.
- Tested prototypes on construction sites and investigated sensor-feedback and system-stability issues.
The software work used Python, Linux and ROS1. Working on the physical system connected the control model, sensor feedback and behaviour observed during field testing.
This project led to my later work on suspended painting robots at C3 Construction Robotics.
Technologies
ROS1 · Linux · Python · Multi-winch Control · Cable Robotics · Sensor Fusion · Field Robotics · Prototyping
Gallery