Overview
C3 Construction Robotics, Mar 2024 – Aug 2026
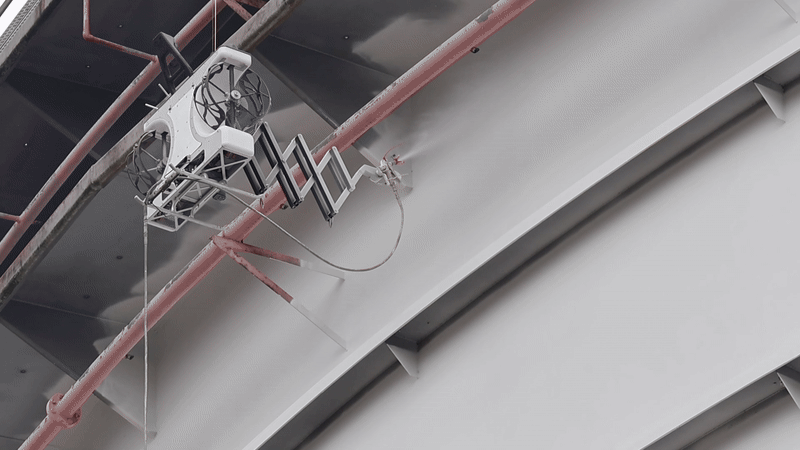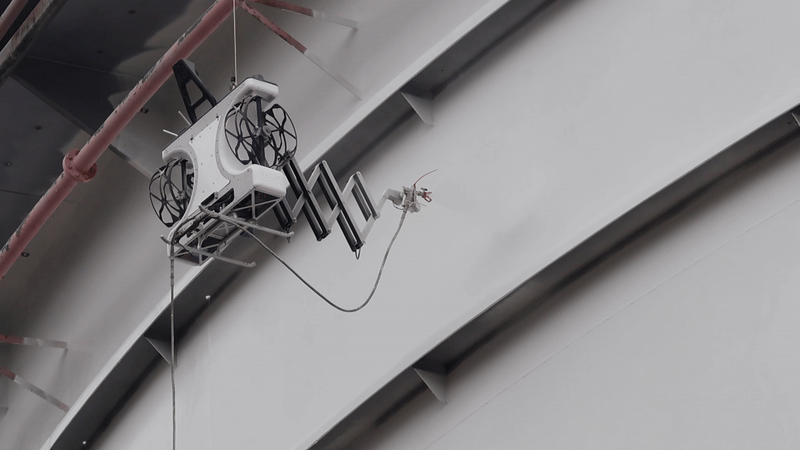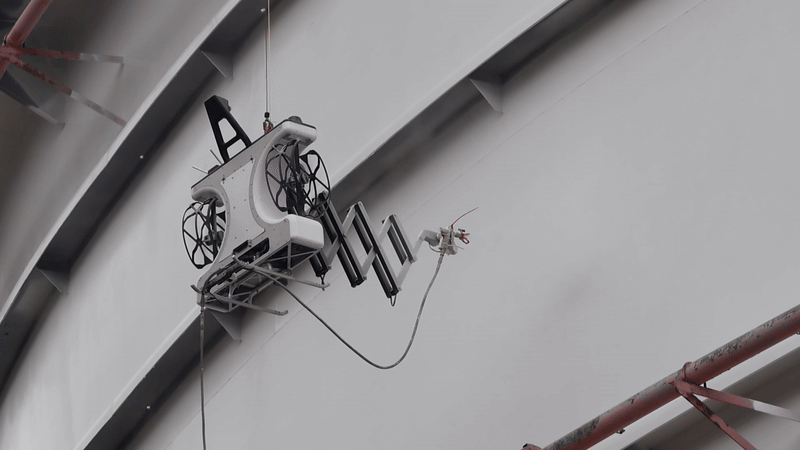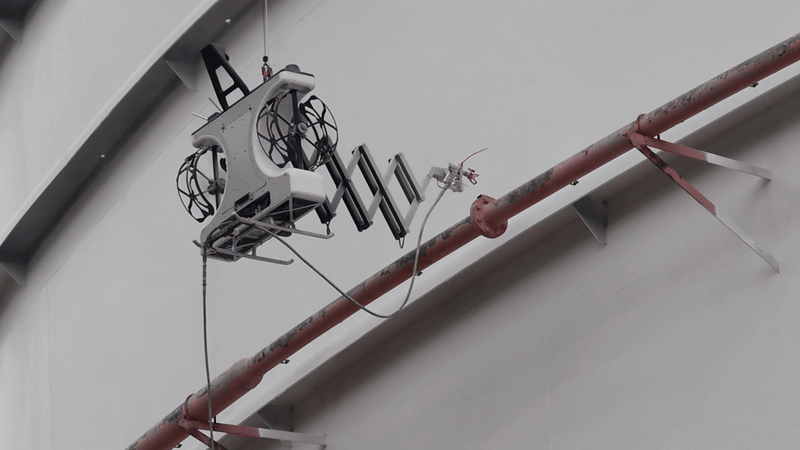
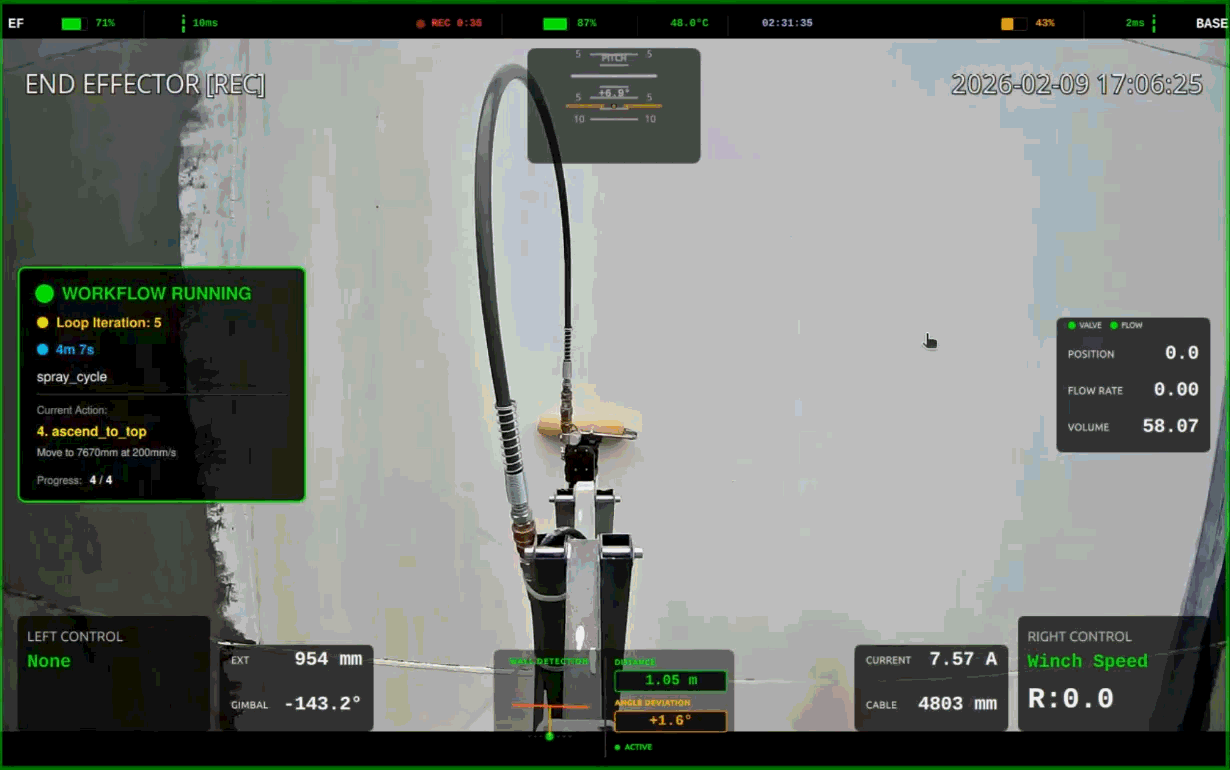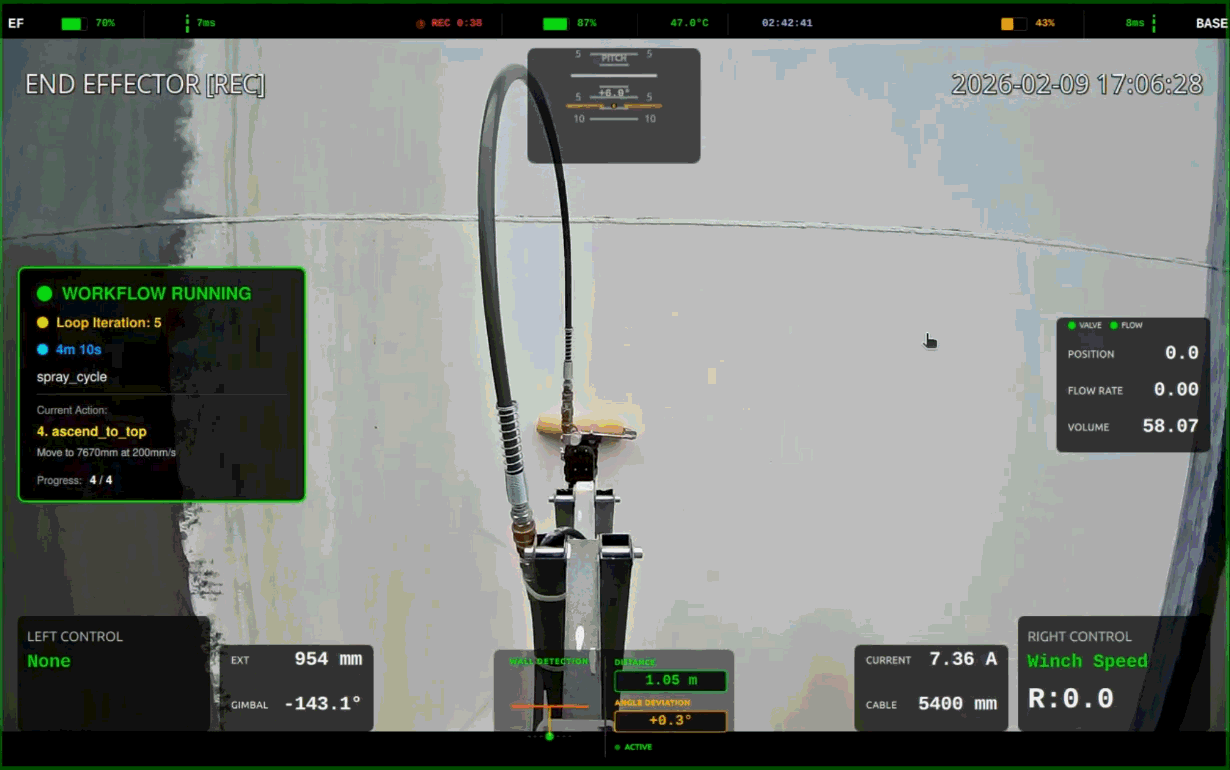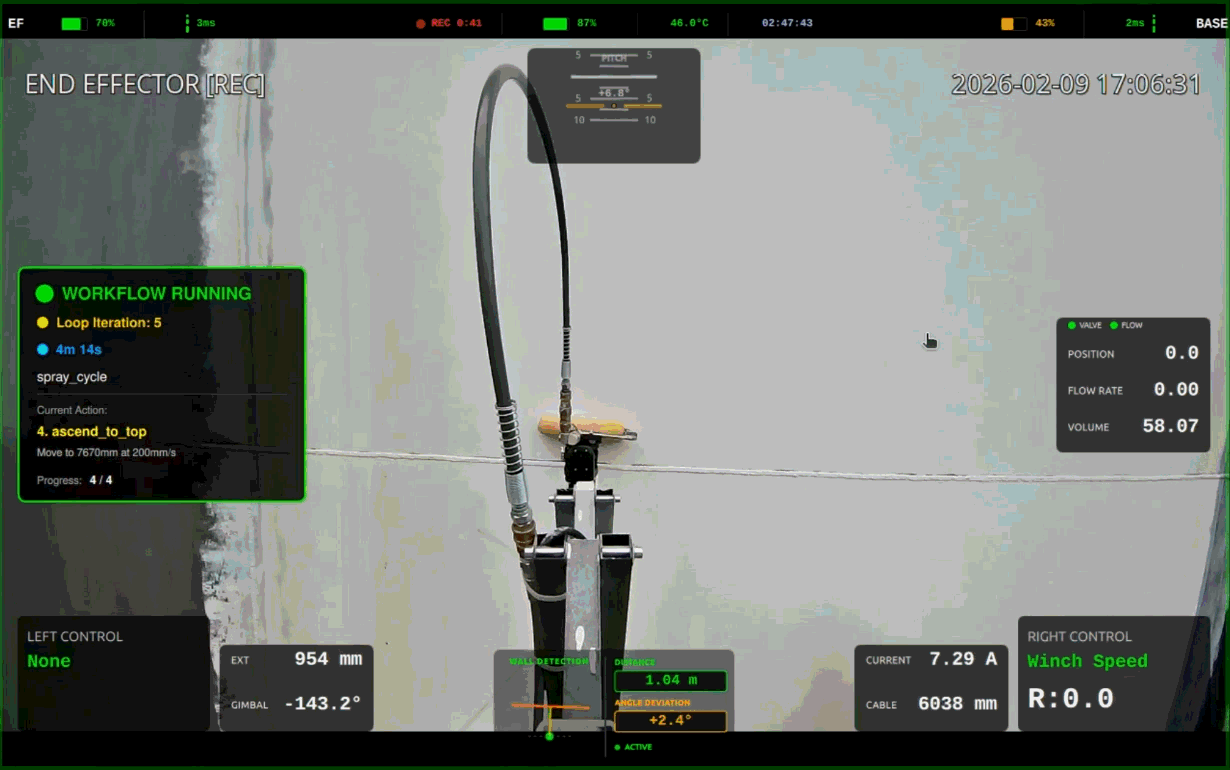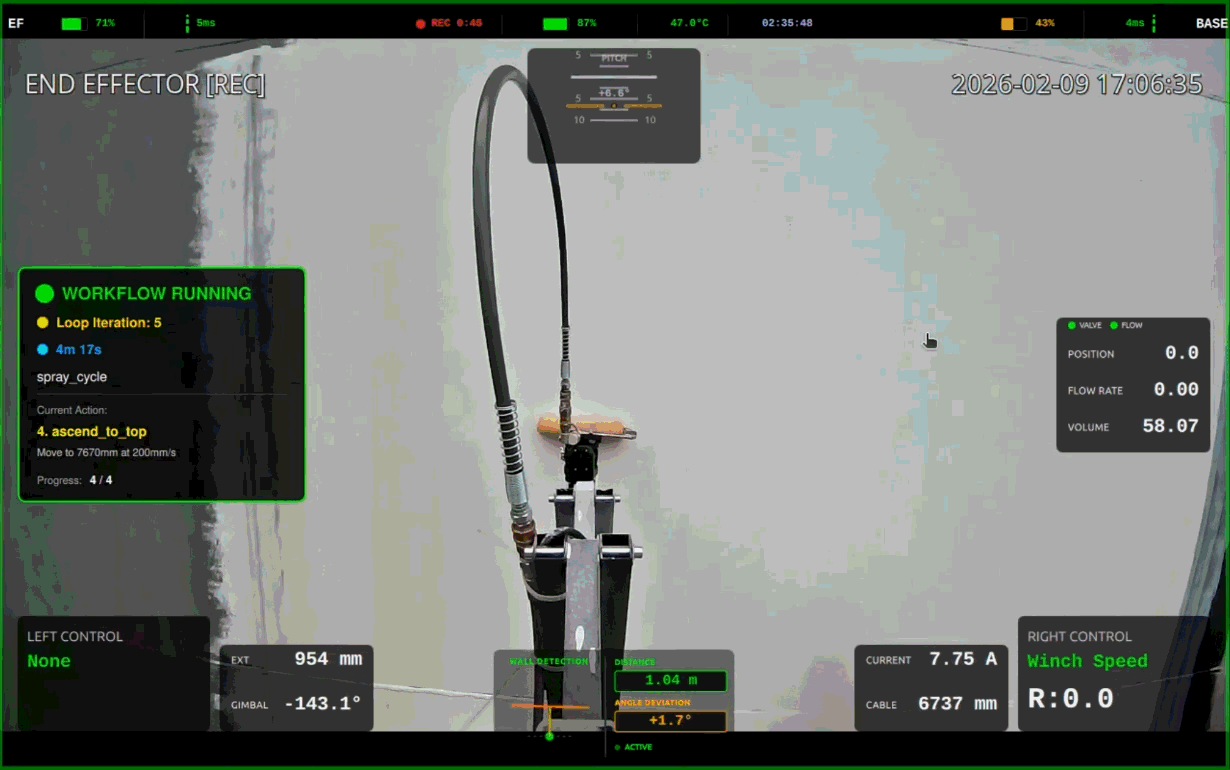
A suspended painting robot for industrial tanks, developed from proof of concept through field deployment. Outdoor operation brought together mechanical design, sensing, control and operator workflows. I was the lead engineer across the hardware and software, including a later roller-end-effector redesign and field testing.
In the News
Mechanical Design
My work covered the suspension frame, propulsion arrangement, end effectors and electronics enclosures. I used CAD, structural analysis and physical prototypes to study mechanical choices and how they affected robot operation and maintenance.
Integration And Control
I developed a distributed ROS2 system connecting winches, the end effector, cameras, LiDAR and embedded controllers through serial and UDP interfaces. The work included sensor integration, pose estimation and prototype control for normal-force regulation and swing damping.
Operator Workflows And Field Operation
The handheld Linux interface uses Python and PySide6/QML for telemetry, camera feeds and workflow sequencing. Position-triggered actions, dependencies and loops coordinate operation across subsystems. Video streaming and recording, network monitoring, health checks and crash recovery supported testing and field troubleshooting.
This project taught me to treat the operator tools and recovery behaviour as part of the robot system, alongside the mechanism and control code.
Technologies: ROS2 · Python · C++ · PySide6/QML · Embedded C++ · Serial / UDP hardware interfaces · NLopt · Sensor fusion · OpenCV · GStreamer · Electronics integration · SolidWorks · SolidWorks Simulation · FEA · 3D printing · Sheet metal · CNC